

Class cv::viz::WCameraPosition#
This 3D Widget represents camera position in a scene by its axes or viewing frustum. :
#include <opencv2/viz/widgets.hpp>Collaboration diagram for cv::viz::WCameraPosition:
Public Member Functions#
Public Member Functions inherited from cv::viz::Widget3D
Return |
Name |
Description |
|---|---|---|
|
Transforms internal widget data (i.e. points, normals) using the given transform. |
|
Returns the current pose of the widget. |
||
|
Sets the color of the widget. |
|
|
Sets pose of the widget. |
|
|
Updates pose of the widget by pre-multiplying its current pose. |
Public Member Functions inherited from cv::viz::Widget
Return |
Name |
Description |
|---|---|---|
|
Casts a widget to another. |
|
|
Returns rendering property of the widget. |
|
|
||
|
Sets rendering property of the widget. |
Static Public Member Functions#
Static Public Member Functions inherited from cv::viz::Widget
Return |
Name |
Description |
|---|---|---|
|
Creates a widget from ply file. |
Additional Inherited Members#
Friends inherited from cv::viz::Widget
Return |
Name |
Description |
|---|---|---|
|
Detailed Description#
This 3D Widget represents camera position in a scene by its axes or viewing frustum. :
Constructor & Destructor Documentation#
WCameraPosition()#
cv::viz::WCameraPosition::WCameraPosition(
const Matx33d & K,
double scale = 1.0,
const Color & color = Color::white() )
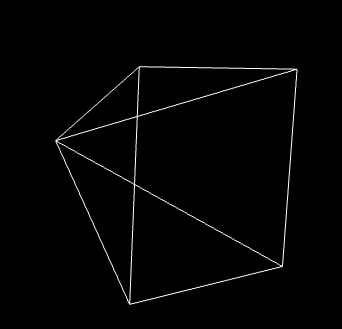
Display the viewing frustum.
Creates viewing frustum of the camera based on its intrinsic matrix K.
Parameters
K— Intrinsic matrix of the camera.scale— Scale of the frustum.color— Color of the frustum.
WCameraPosition()#
cv::viz::WCameraPosition::WCameraPosition(
const Matx33d & K,
InputArray image,
double scale = 1.0,
const Color & color = Color::white() )
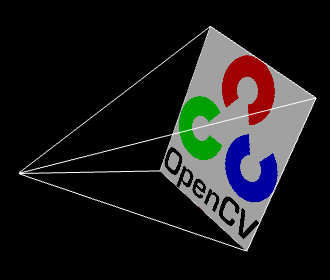
Display image on the far plane of the viewing frustum.
Creates viewing frustum of the camera based on its intrinsic matrix K, and displays image on the far end plane.
Parameters
K— Intrinsic matrix of the camera.image— BGR or Gray-Scale image that is going to be displayed on the far plane of the frustum.scale— Scale of the frustum and image.color— Color of the frustum.
WCameraPosition()#
cv::viz::WCameraPosition::WCameraPosition(
const Vec2d & fov,
double scale = 1.0,
const Color & color = Color::white() )
Display the viewing frustum.
Creates viewing frustum of the camera based on its field of view fov.
Parameters
fov— Field of view of the camera (horizontal, vertical).scale— Scale of the frustum.color— Color of the frustum.
WCameraPosition()#
cv::viz::WCameraPosition::WCameraPosition(
const Vec2d & fov,
InputArray image,
double scale = 1.0,
const Color & color = Color::white() )
Display image on the far plane of the viewing frustum.
Creates viewing frustum of the camera based on its intrinsic matrix K, and displays image on the far end plane.
Parameters
fov— Field of view of the camera (horizontal, vertical).image— BGR or Gray-Scale image that is going to be displayed on the far plane of the frustum.scale— Scale of the frustum and image.color— Color of the frustum.
WCameraPosition()#
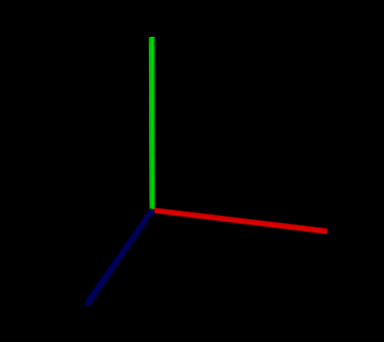
cv::viz::WCameraPosition::WCameraPosition(double scale = 1.0)
Creates camera coordinate frame at the origin.
Source file#
The documentation for this class was generated from the following file:
opencv2/viz/widgets.hpp